Current status
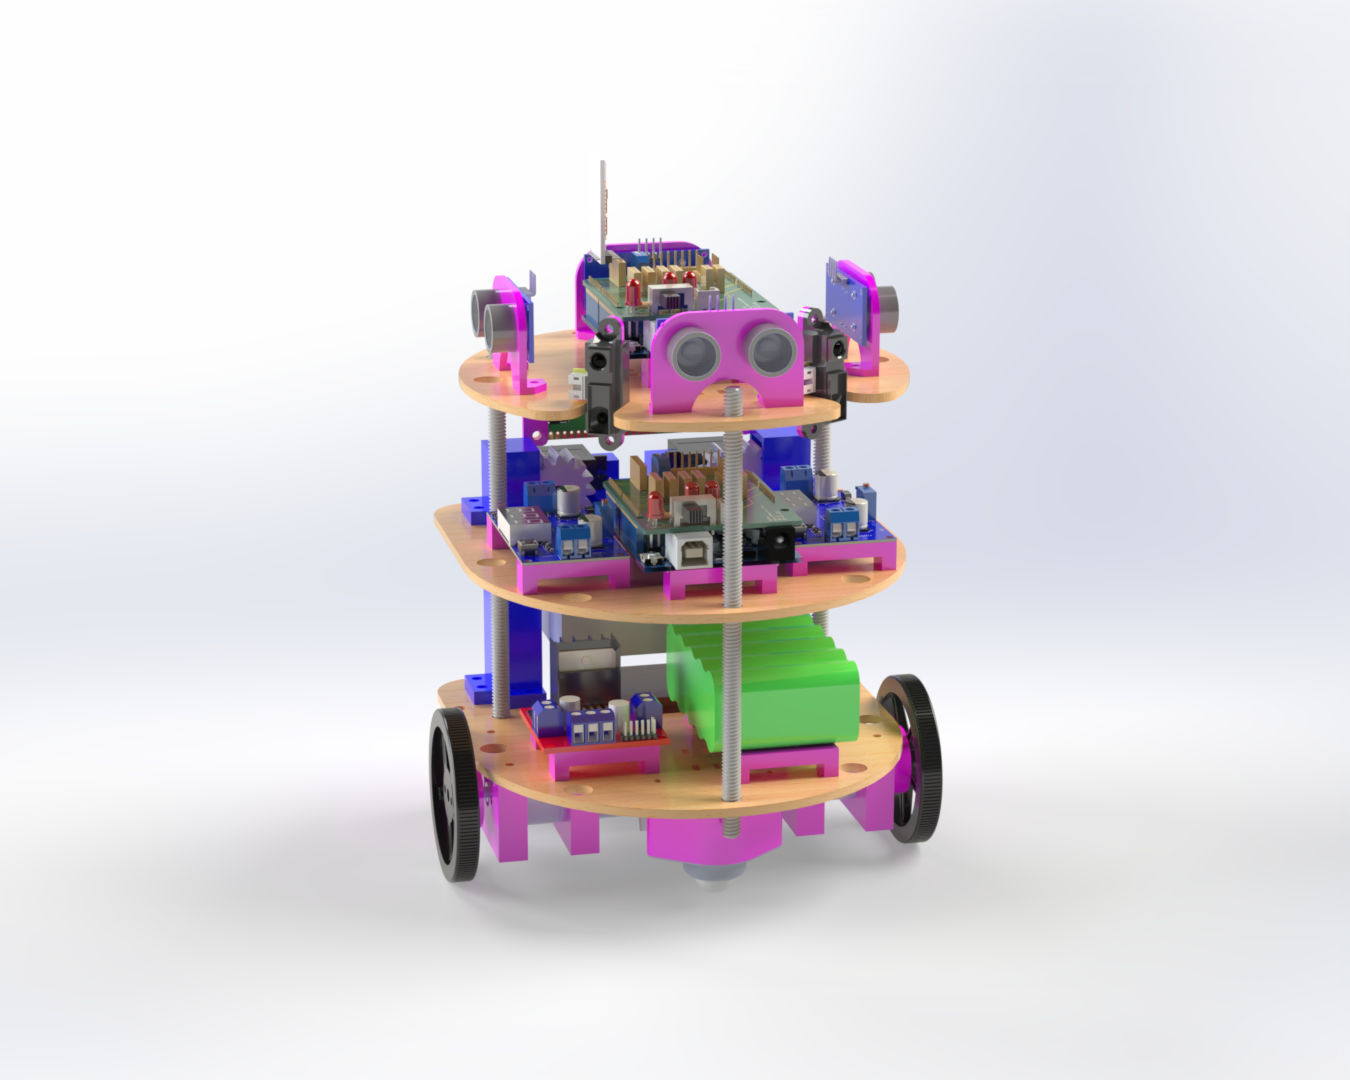
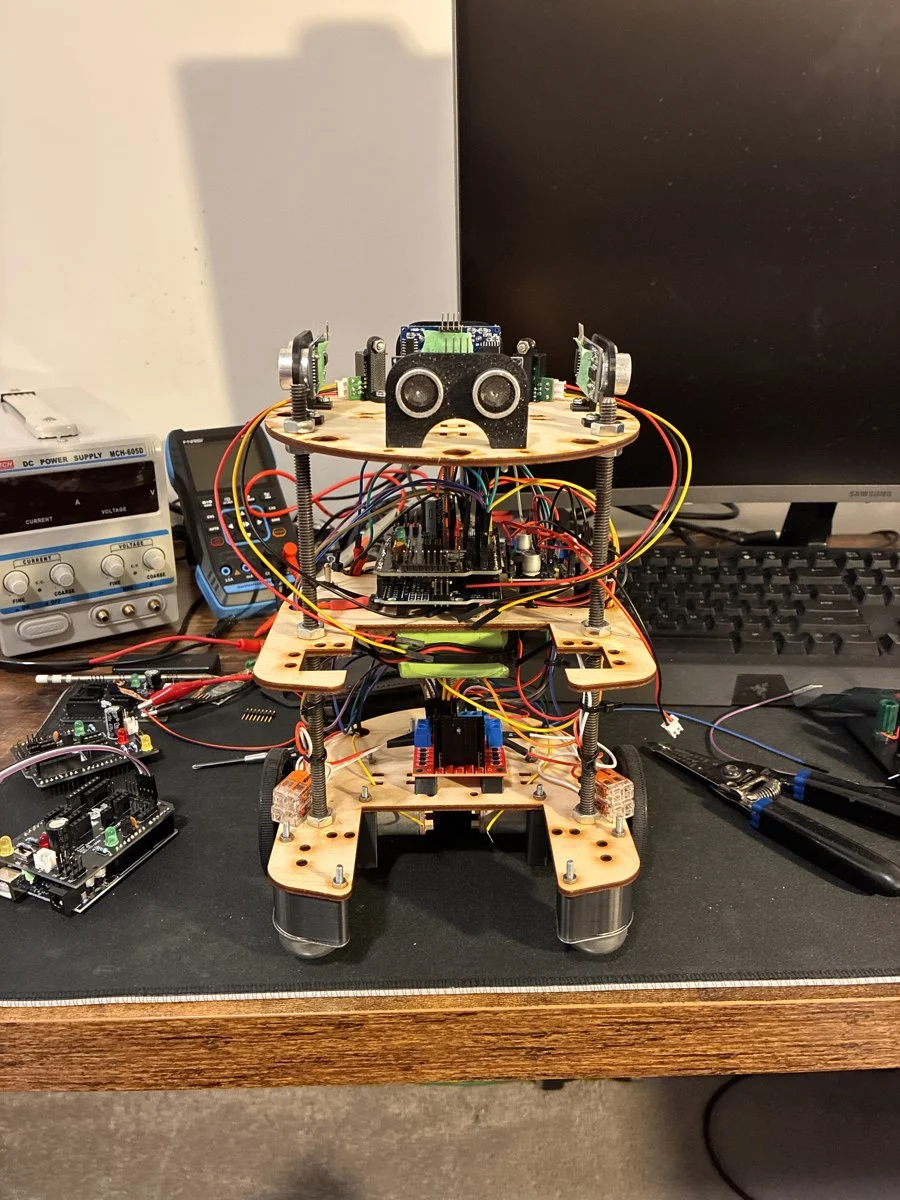
In progress. The video and images show the current build and CAD assembly; autonomous navigation and block-handling results will be added as the project develops.
My contributions
I am responsible for mechanical design, including CAD and robot assembly. I am also responsible for the drivetrain, and I am currently working on a PID loop to control motor speed.
Robot video
Design and build
The task
- Navigate a maze autonomously.
- Pick up a block.
- Deliver it to a target location.